|
Hoseong Jung I'm a PhD student in the Interdisciplinary Program in Artificial Intelligence at Seoul National University, working at Lab for Autonomous Robotics Research (LARR) under the guidance of Prof. H. Jin Kim. My research focuses on cooperative intelligence within multi-agent embodied systems. Before joining LARR, I was a research officer at the Defense AI Center of the Agency for Defense Development (ADD). I completed my bachelor's degree in Electrical and Computer Engineering at the Seoul National University. I hope my research leads to assistant robots that bring care and support to children and people with disabilities. |
|
News
|
Selected Publications |
|
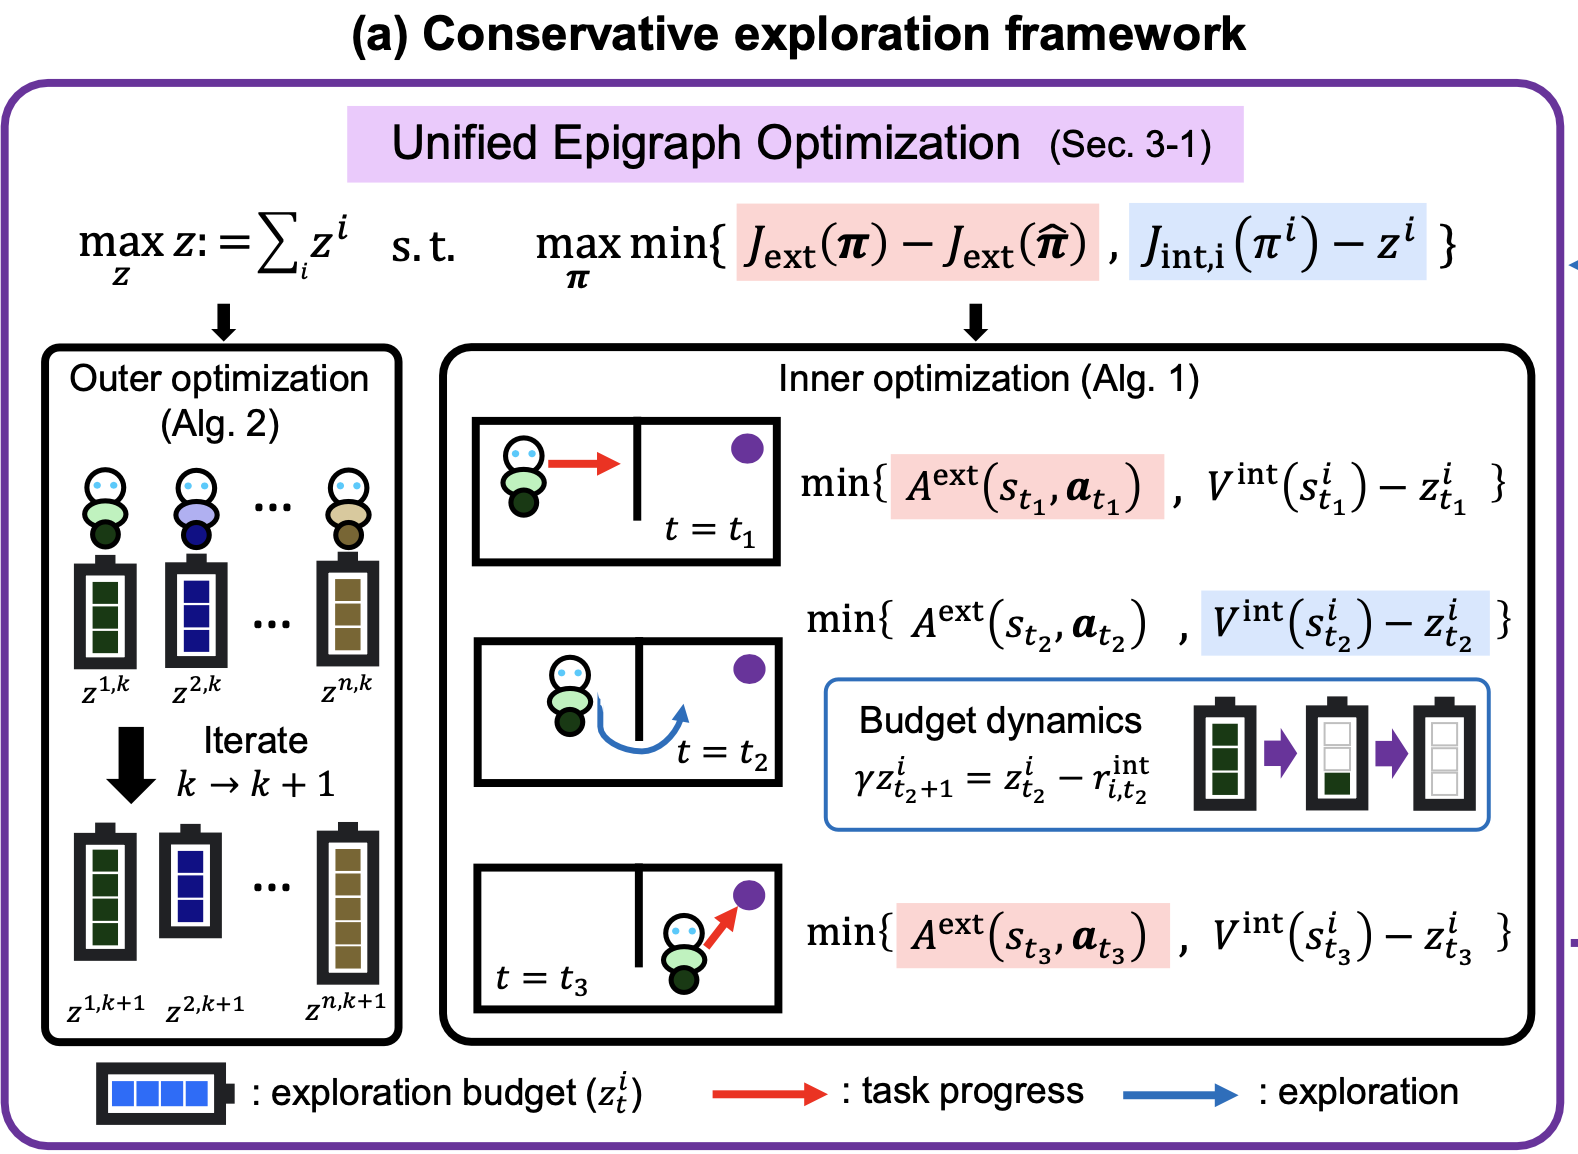
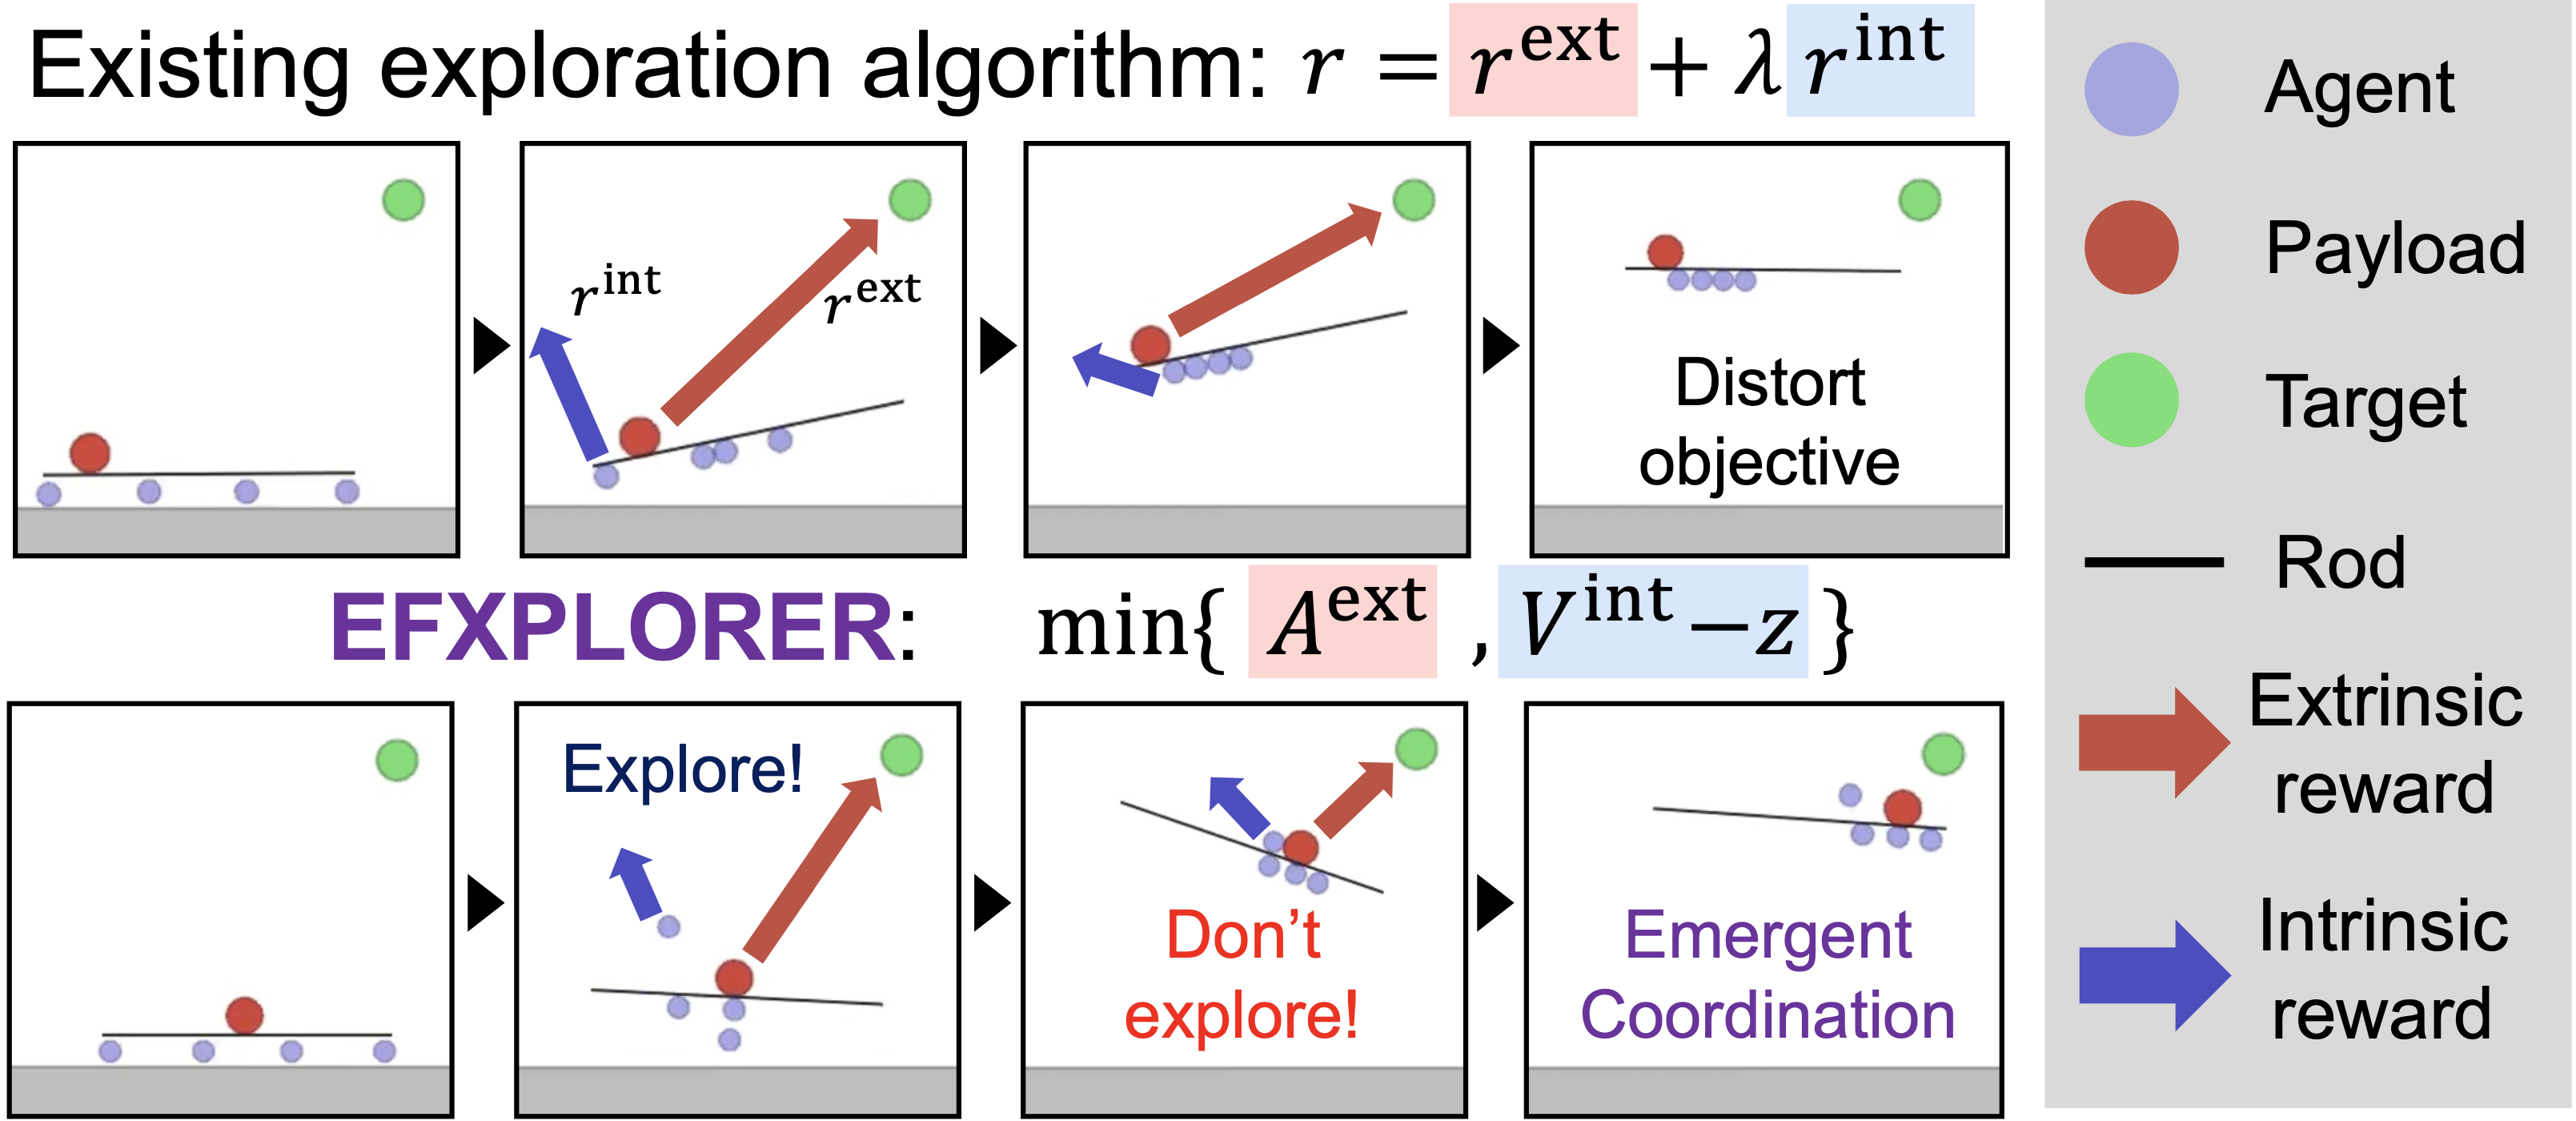
Cooperative Multi-Agent Reinforcement Learning via Epigraph-Form Guided Exploration
Sungil Son*, Hoseong Jung*, Dahyun Oh*, H. Jin Kim NeurIPS, 2026
project page In this paper, we propose EFXPLORER, a constrained exploration framework that maximizes exploration objectives subject to a constraint that preserves established task performance. |
|
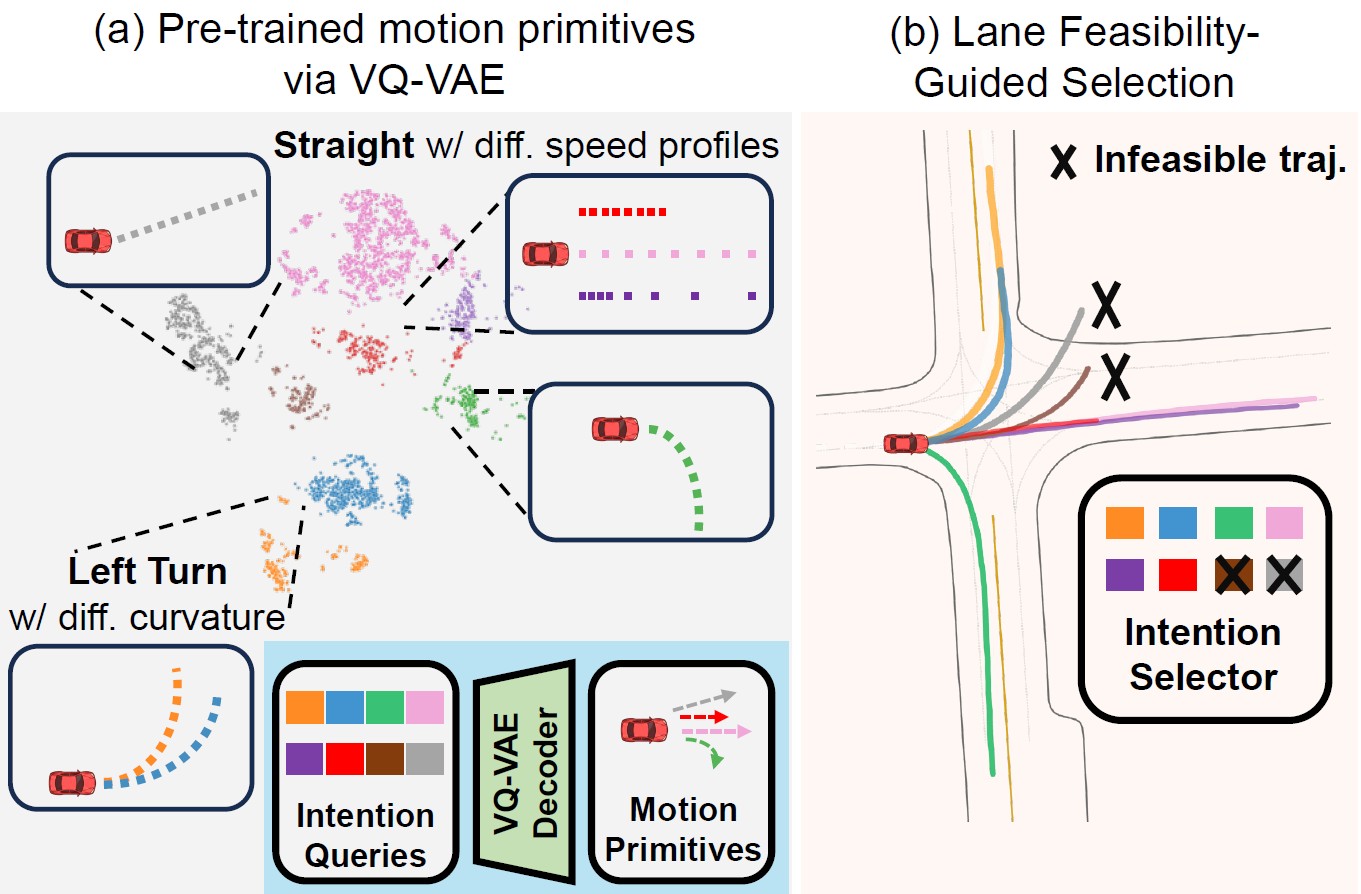
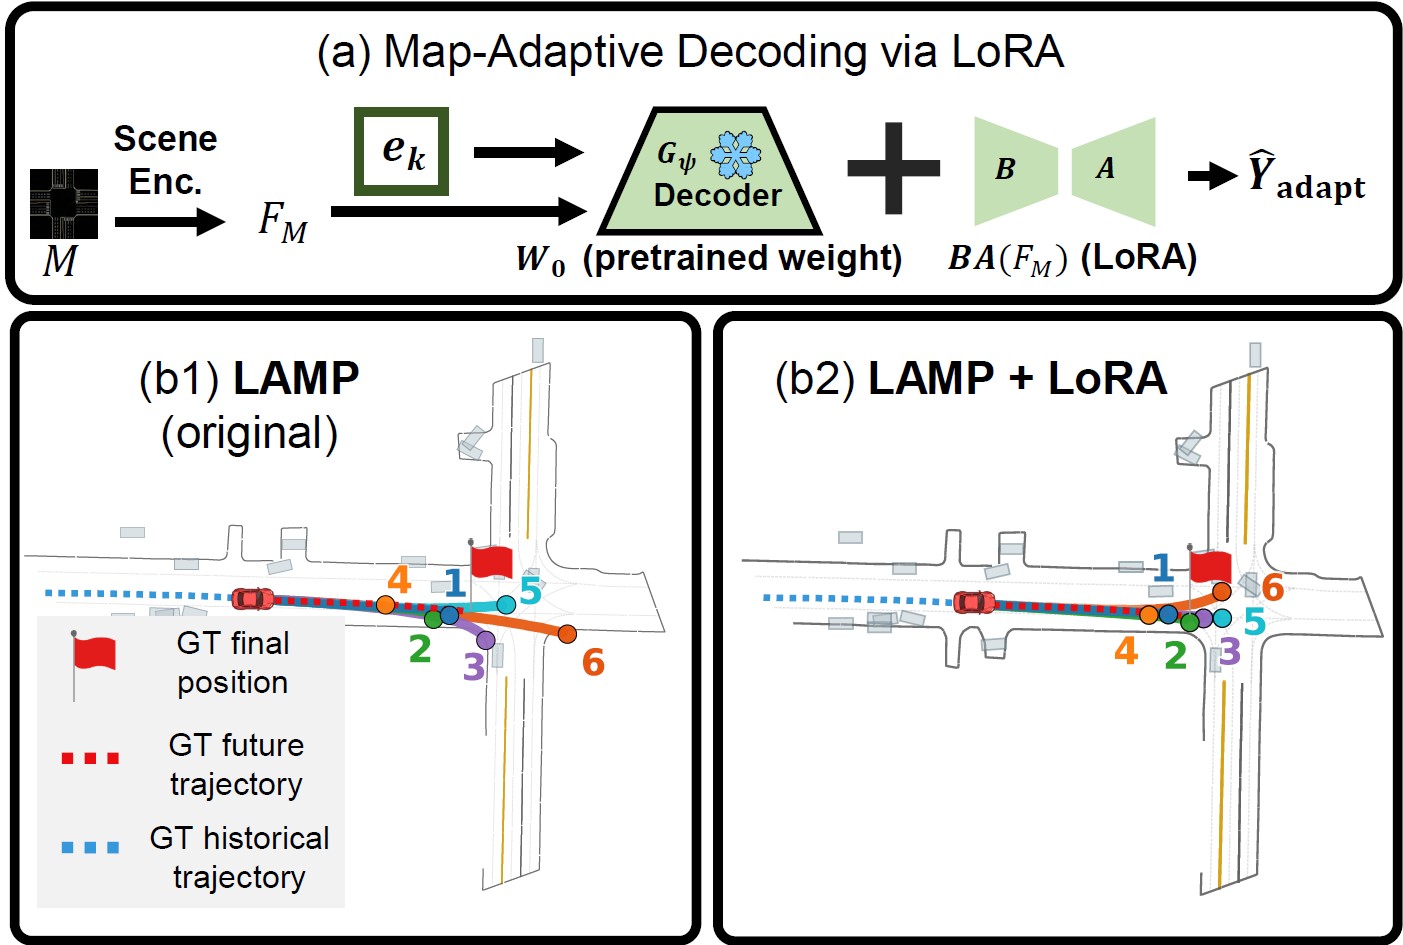
LAMP: Lane-Aligned Motion Primitives for Feasible Trajectory Prediction
Sangjin Han*, Hoseong Jung*, Jeongtae Her*, Changhyun Choi, H. Jin Kim ICRA workshop on Generalization in Autonomous Driving, 2026
IEEE International Conference on Intelligent Transportation Systems (ITSC), 2026
paper / project page In this paper, we propose a topology-aware forecasting framework designed to improve the structural reliability of multimodal predictions across varying road geometries. |
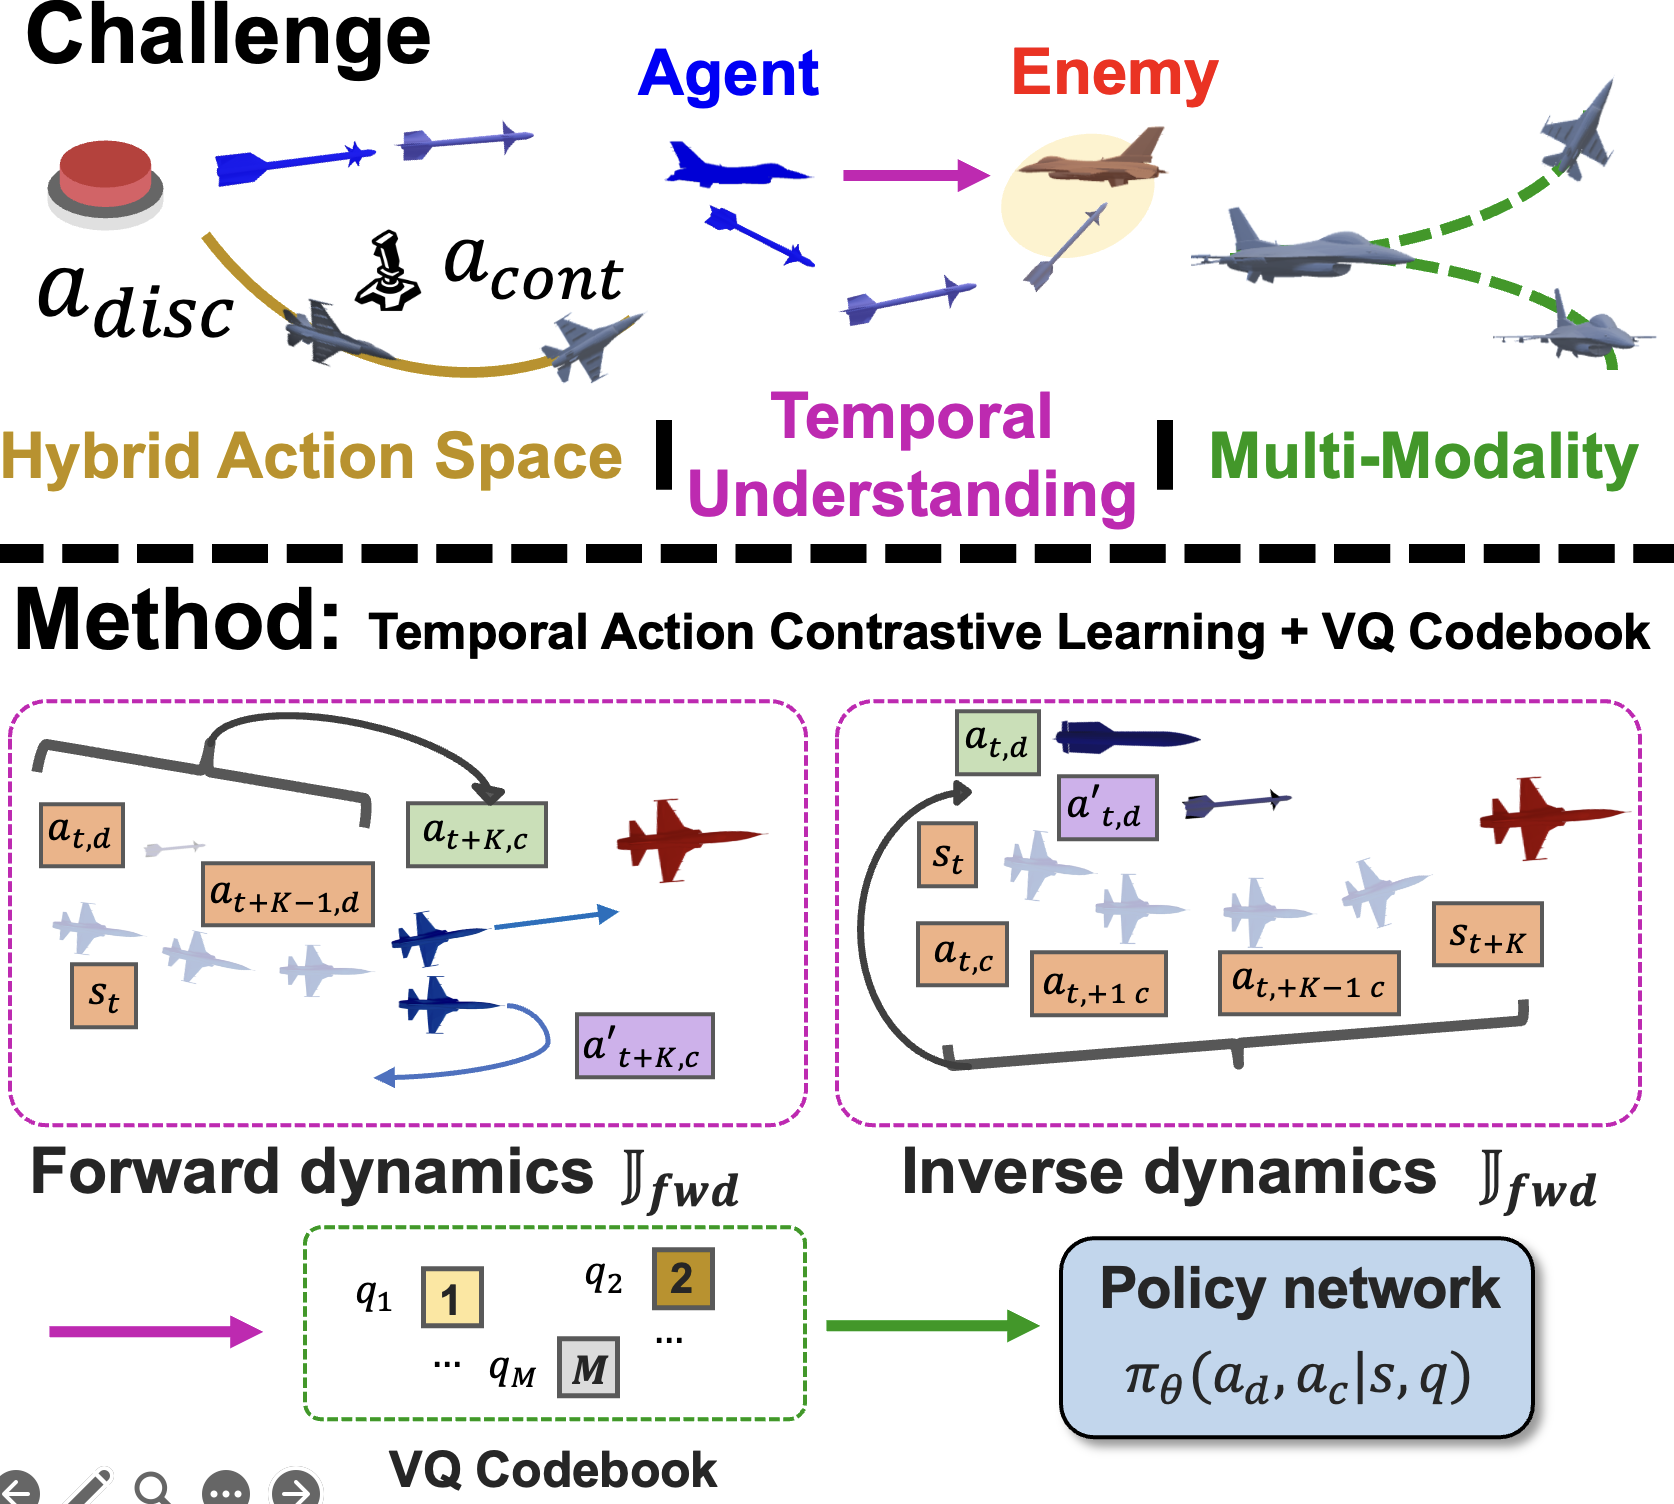 |
Temporal Action Representation Learning for Tactical Resource Control and Subsequent Maneuver Generation
Hoseong Jung, Sungil Son, Daesol Cho, Jonghae Park, Changhyun Choi, H. Jin Kim IEEE International Conference on Robotics and Automation (ICRA), 2026
RSS workshop on Leveraging Implicit Methods for Aerial Autonomy, 2025
paper / project page In this paper, we introduce a temporal action contrastive learning approach that facilitates semantic alignment between resource control and tactical maneuvers. |
|
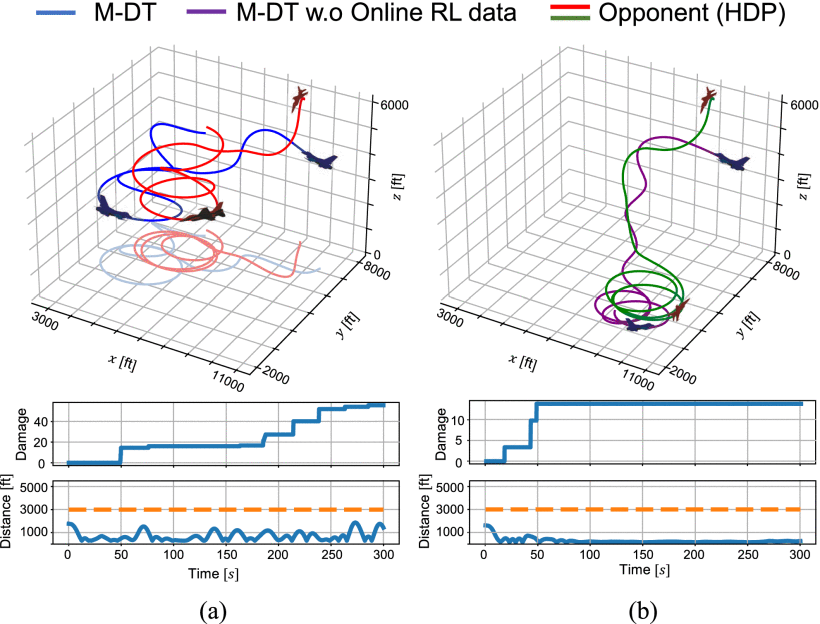
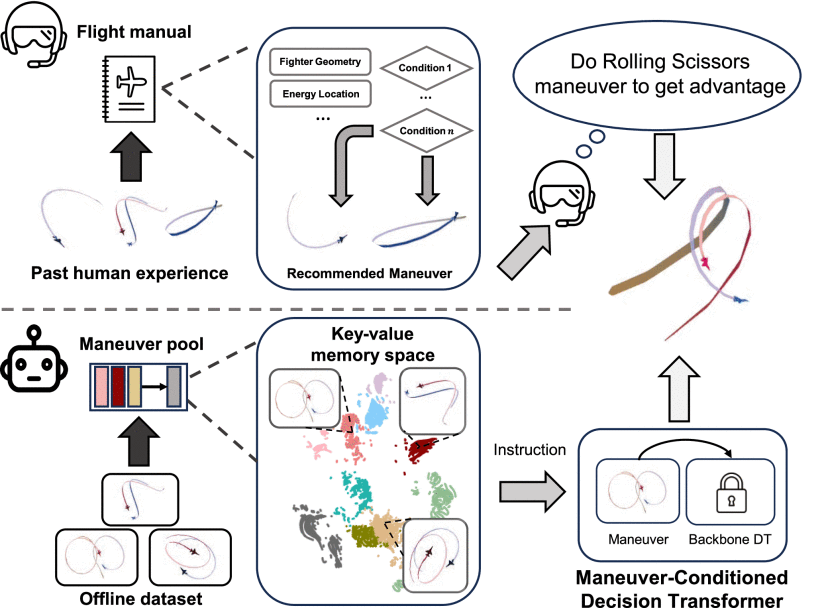
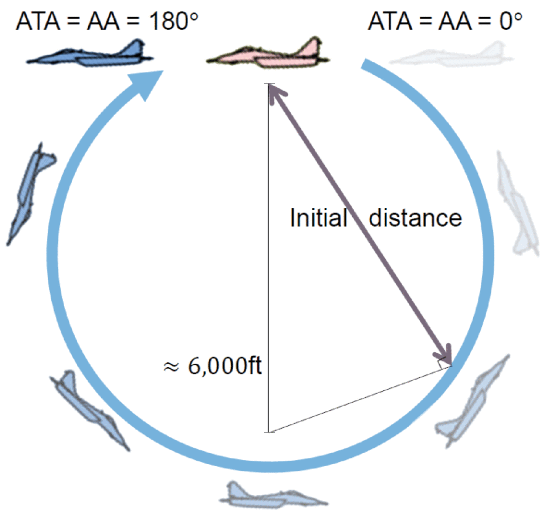
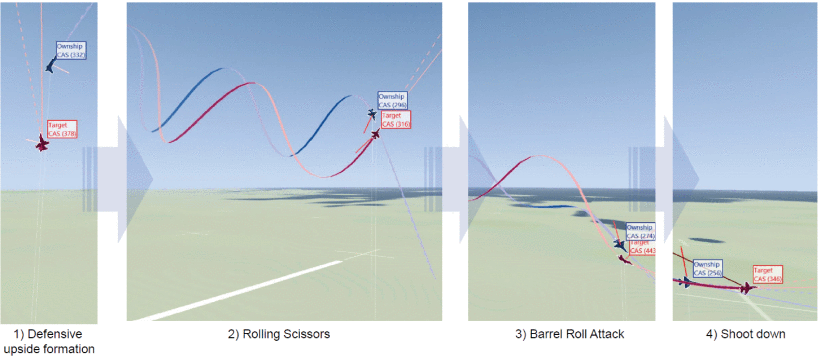
Maneuver-Conditioned Decision Transformer for Tactical in-Flight Decision-Making
Hoseong Jung, Yong-Duk Kim, Youngjung Kim IEEE Robotics and Automation Letters, 2024 paper In this paper, we explore the offline reinforcement learning framework for tactical air combat. |
|
Deep Reinforcement Learning-Based Air-to-Air Combat Maneuver Generation in a Realistic Environment
Jung Ho Bae, Hoseong Jung, Seogbong Kim, Sungho Kim, Yong-Duk Kim IEEE Access, 2023 paper In this paper, we propose a deep reinforcement learning-based framework for developing a model capable of performing within visual range (WVR) air-to-air combat under the conditions of a partially observable Markov decision process (POMDP) with insufficient information. |
Projects |
|
|
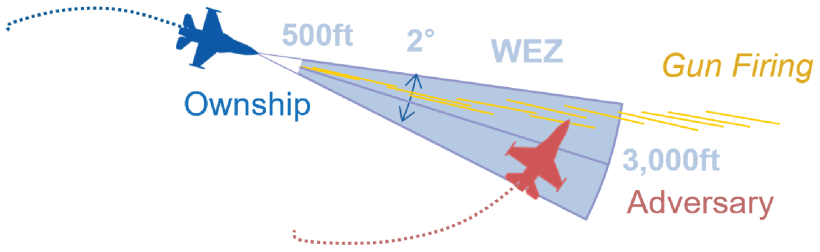
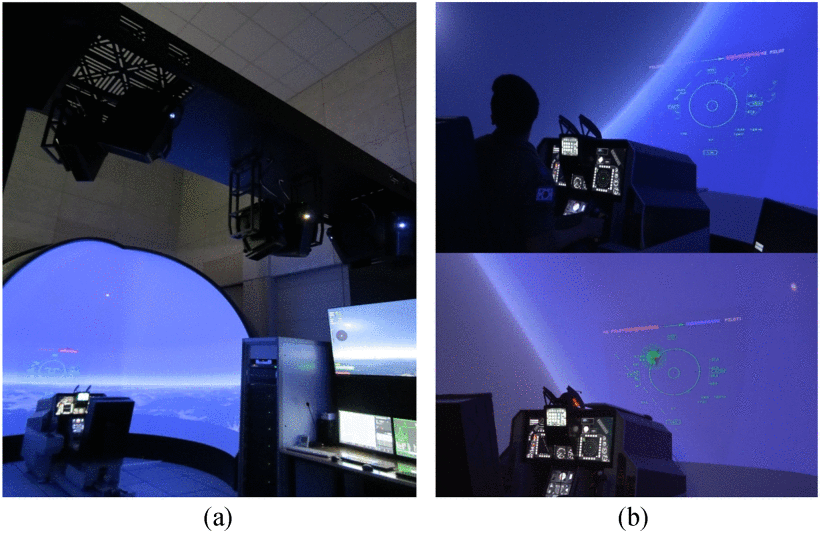
AI for Air Combat Engagement
Agency for Defense Development, 2022 - 2023 In this project, we develop both heuristic-based and learning-based agent performing within visual range (WVR) air-to-air combat. |
Awards
|
|
Feel free to steal this website's source code. Do not scrape the HTML from this page itself, as it includes analytics tags that you do not want on your own website — use the github code instead. Also, consider using Leonid Keselman's Jekyll fork of this page. |